Structured environment scans tailored to your training needs.
Before-and-after photos, video, LiDAR, and labels from each kitchen.
Harvard’s Computational Robotics Group used our kitchen captures to build a robot simulation environment with SceneAgent, turning a real home into a scene with articulated cabinets and appliances.
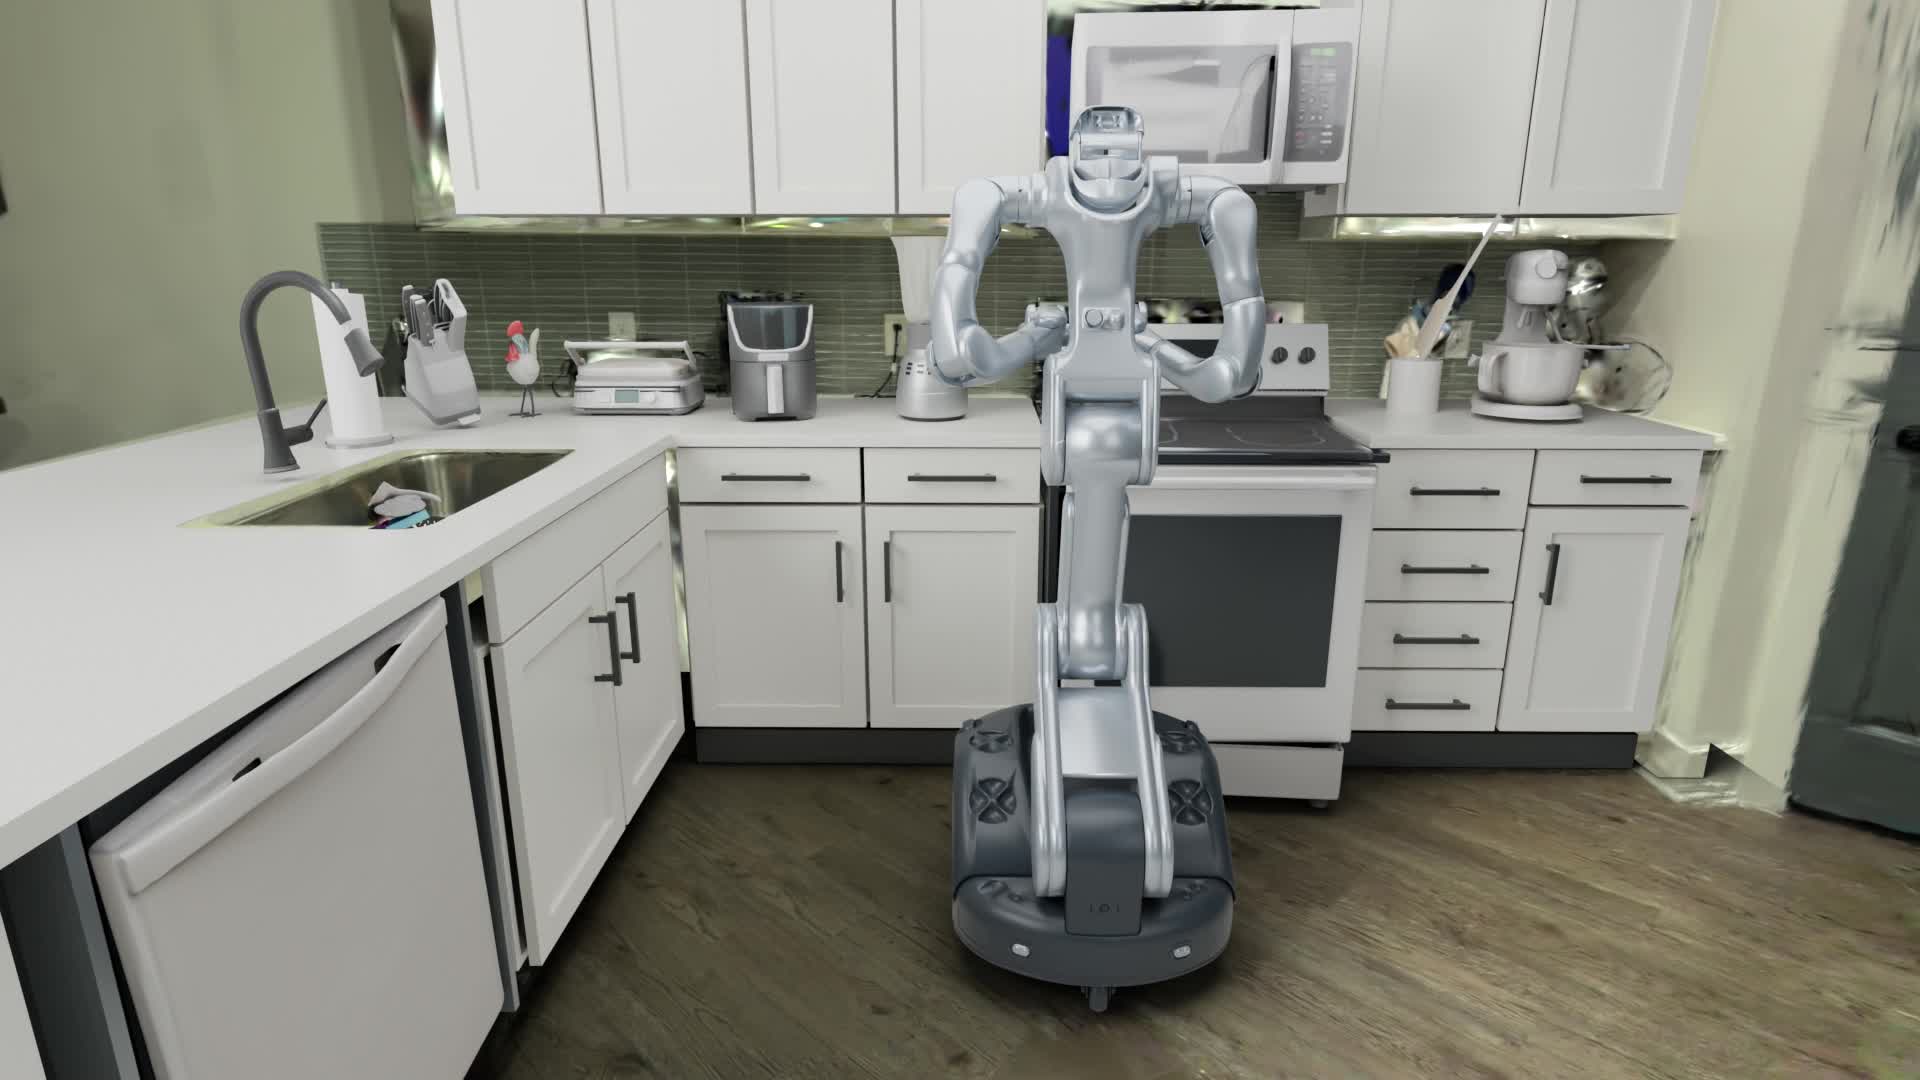
SceneAgent · Harvard Computational Robotics Group
Luke Hollis, Tianxing Fan & Heng Yang.
Kitchen captures by CollectData. Reconstruction and simulation by SceneAgent.
| Before — messy | ||
| 1 | Scan your messy kitchen | PAID |
| 2 | Widest possible photo of your messy kitchen | PAID |
| 3 | Photo of the messiest counter | PAID |
| 4 | Label the messy counter | PAID |
| 5 | Closeup photo #1 | PAID |
| 6 | Label photo #1 | PAID |
| 7 | Closeup photo #2 | PAID |
| 8 | Label photo #2 | PAID |
| 9 | Closeup photo #3 | PAID |
| 10 | Label photo #3 | PAID |
| 11 | Messy kitchen video tour (naming items to tidy) | PAID |
| After — tidied | ||
| 12 | Photo of the clean counter | PAID |
| 13 | Scan your clean kitchen | PAID |
| 14 | Widest possible photo of your clean kitchen | PAID |
| 14 tasks, one kitchen | PAID | |
Need the paperwork before the data? Ask us for the release text and licence terms →
LiDAR scans and guided photo passes of open refrigerators - shelf-level geometry with per-item photos, for inventory and grasping datasets.
Head-mounted first-person video of full laundry routines - sorting, loading, folding - with task narration, for household-robotics training.
A closer look at the Tidy-Up pilot and the data behind every scene.
Tell us what you're building and we'll get back to you. Looking for the sample? Download the dataset.